SummerHacks & Me
Spark
3D graphics
spatial interfaces
Project overview
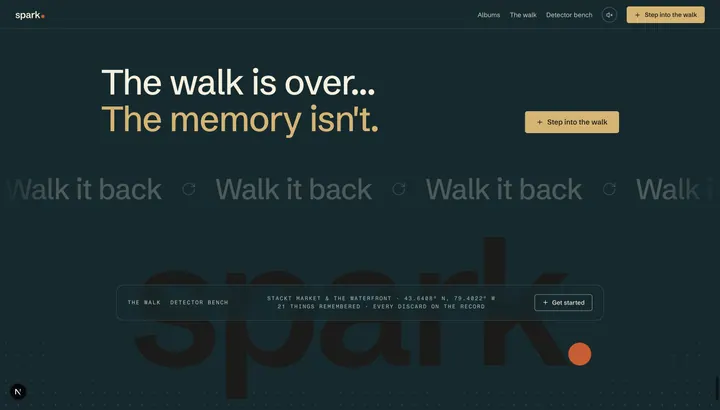
A rover walks with you and keeps the moments worth keeping
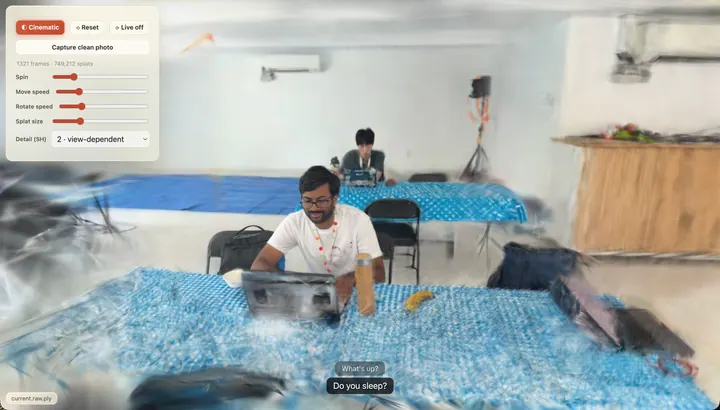
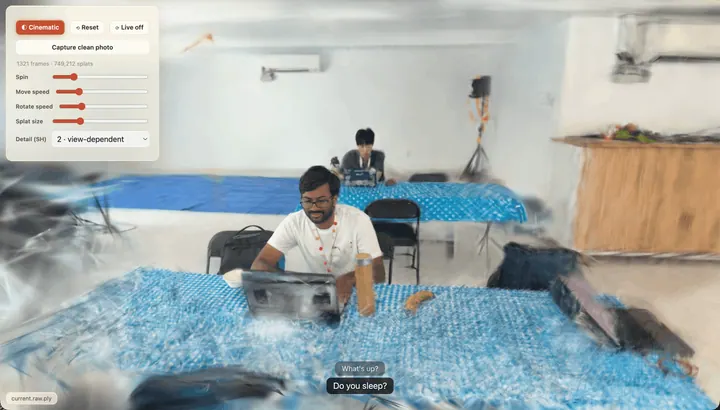
A companion robot films a walk, decides on its own which minutes mattered, and rebuilds each one as a Gaussian splat you can walk back into.
Role
- Front-end engineer
- day atlas and globe
- splat viewer
- detection-to-moment pipeline
- design
Date
August 2026
Field
Full-stack
Stack
TypeScript, Next.js, React Three Fiber, MapLibre, Gaussian splatting, Transformers.js
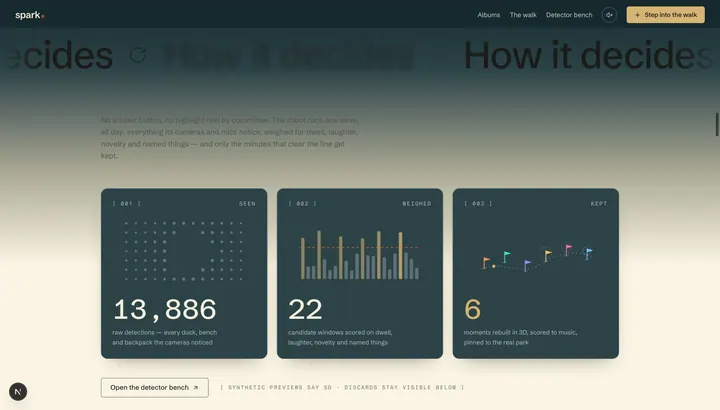
13,886 detections to 6 kept moments
749,212 splats in one moment
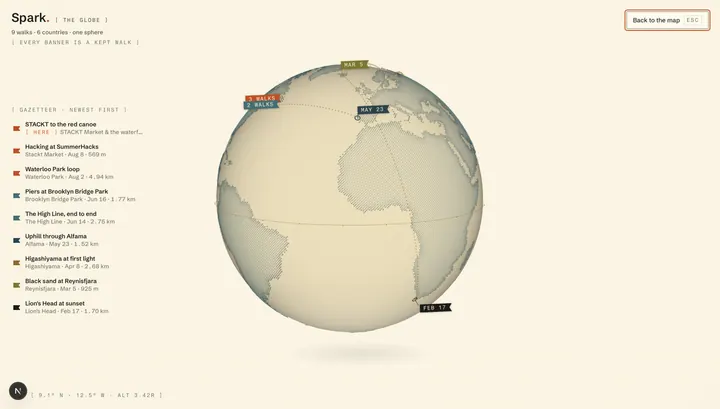
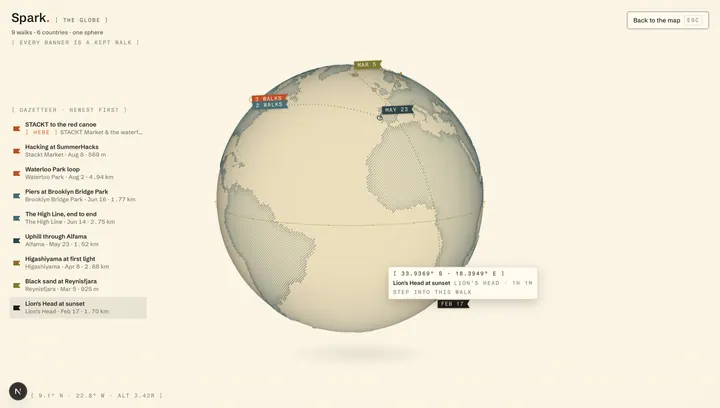
9 walks on one globe
Context
Built at SummerHacks with Matthew Sakhno, Jack Le and Sai Jilla. An iPhone and a speaker ride an ESP32 rover; I built the whole web half — the four-view app the walk comes back as.
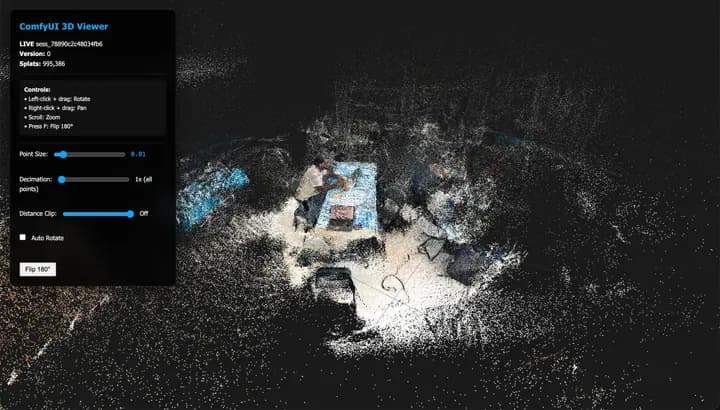
Spark
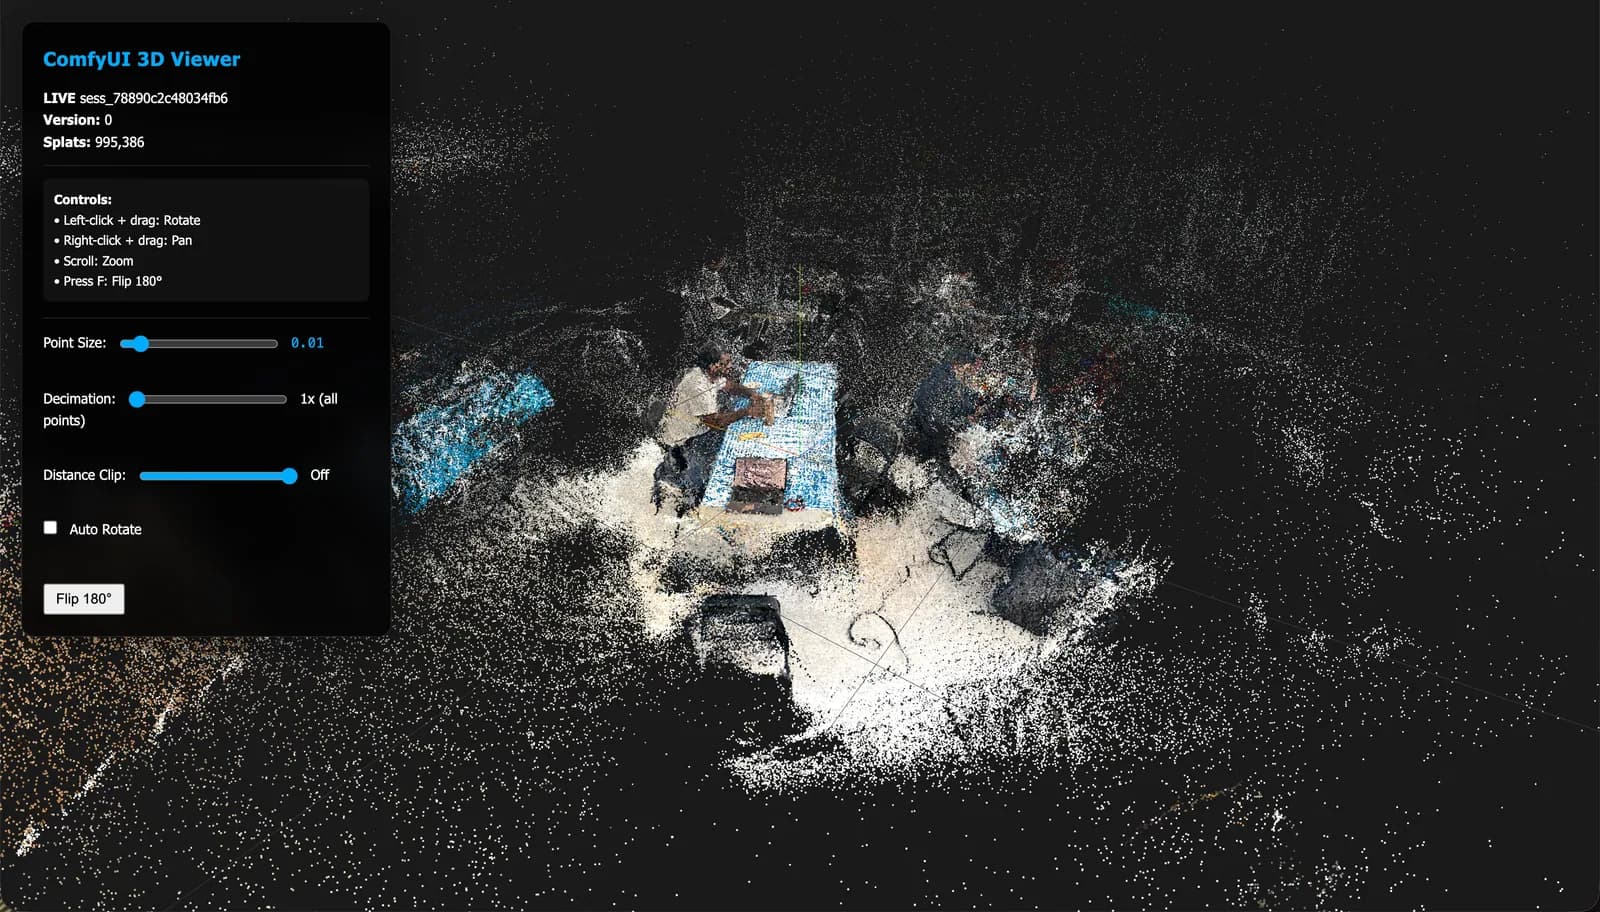
A photo roll is a pile of stills with no place and no order.
The hard part
The interesting problem is not capturing more, it is deciding — without a shutter button — which minutes of a walk were worth keeping, and then giving them somewhere to live.
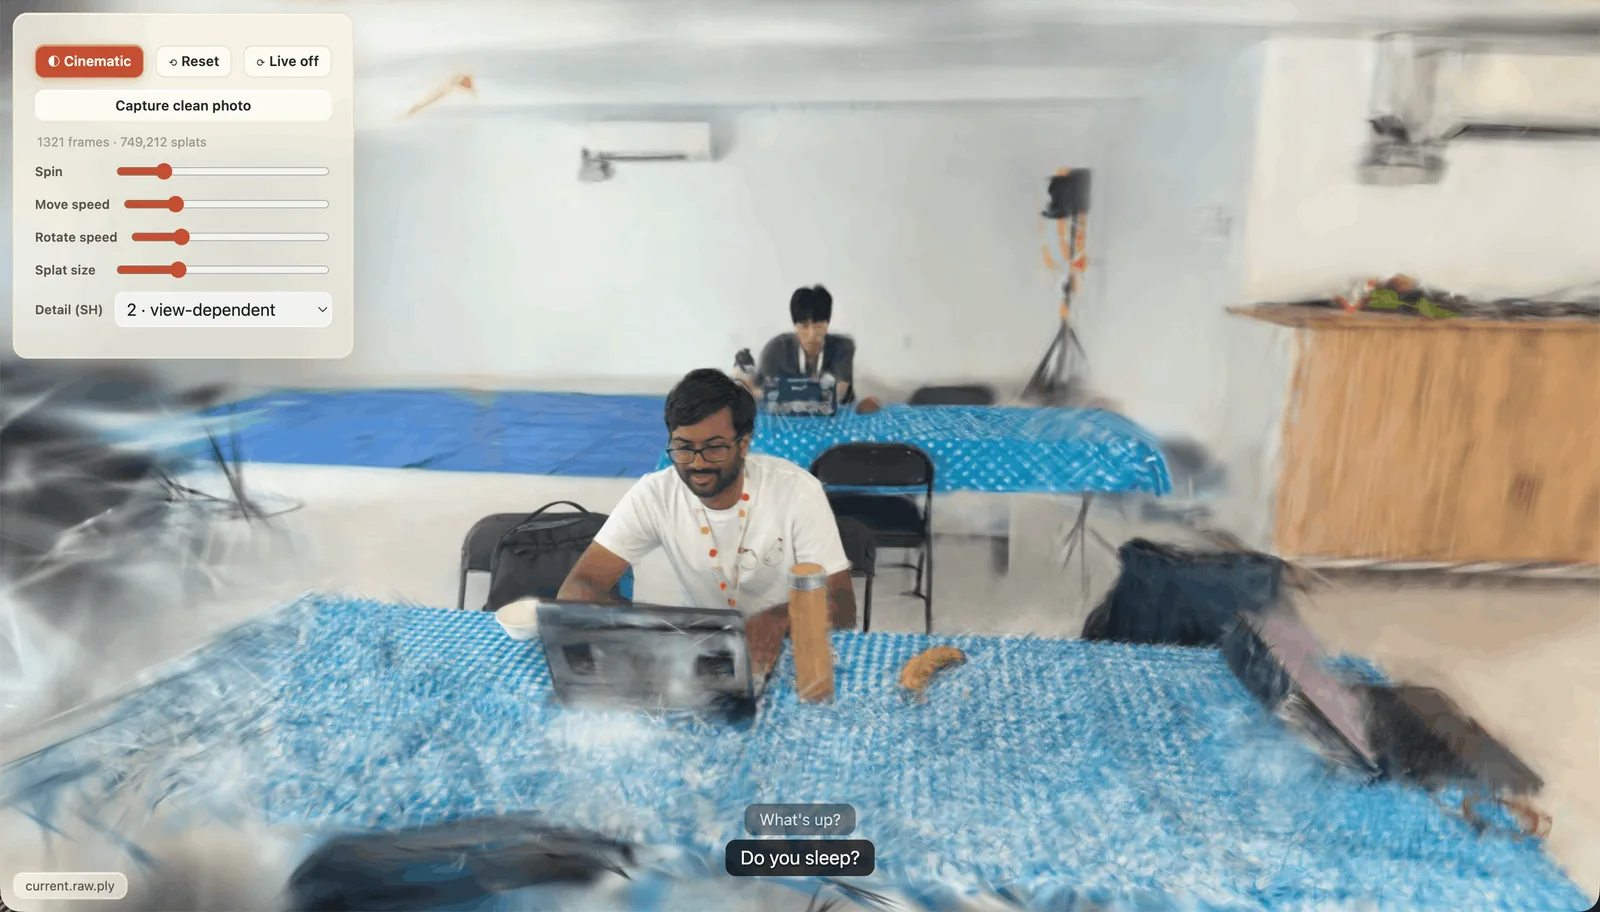
What it took
- Built one sieve — dwell, laughter, novelty, named things — that scored 22 candidate windows out of 13,886 raw detections and kept 6.
- Kept every discard visible in a detector bench, so the robot's judgment can be audited rather than trusted.
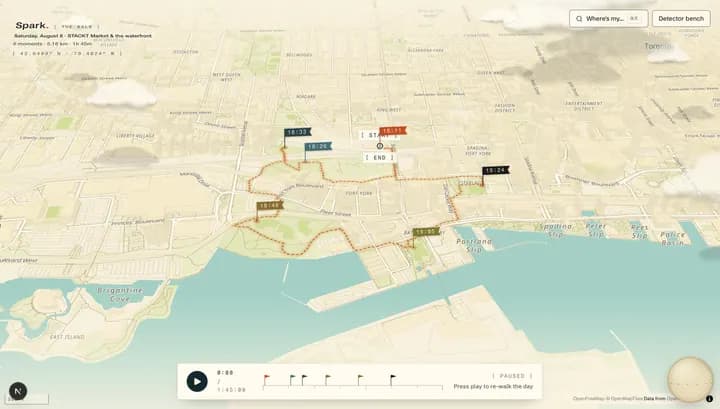
- Pinned each kept moment to its real minute and metre on the route, then let the atlas zoom out into a globe of every walk.
- Ran object detection client-side in multiple passes with test-time augmentation, so nothing left the browser to be labelled.
Outcome
Awards &Recognition
SummerHacks
1st place overall